Custom EOAT manufacturing · Shenzhen
Custom Plastic Robot Grippers, Built to Your CAD
Plasticpartsmfg manufactures precision plastic grippers, fingers, and end-of-arm tooling (EOAT) for robotics integrators, automation equipment suppliers, and production-line OEMs. From functional prototypes to small-batch production, we build to your material, tolerance, and assembly requirements.
±0.02–0.1 mm
Tolerance range*
CNC + 3D print
Rapid iteration
Prototype to batch
Flexible production
*Achievable tolerance depends on part geometry and manufacturing process.
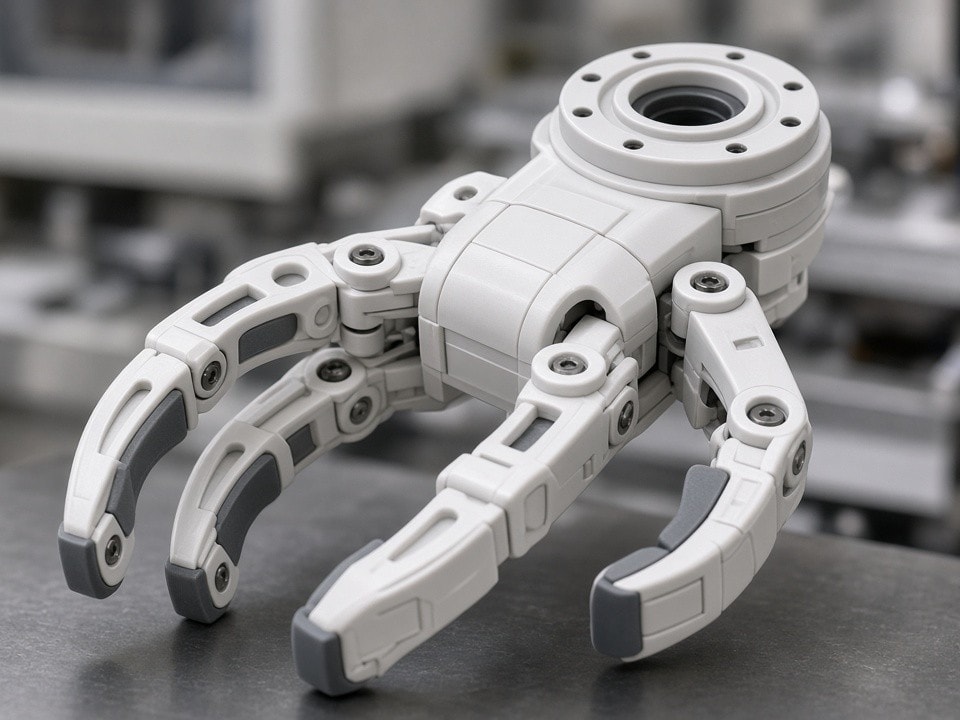
Designed around your application
Low-inertia components, soft-contact gripping surfaces, vacuum interfaces, and quick-change mounting features made to drawing.
Manufacturing capabilities
Precision parts for reliable automation
We combine CNC machining, 3D printing, and vacuum casting to produce gripper geometries that balance structural rigidity with low inertia. Custom contours can be matched to the part, while mounting holes and vacuum channels are incorporated to suit your tooling design.
- Primary processes
- CNC machining, 3D printing, vacuum casting
- Material options
- POM, PEEK, PA (nylon), ABS, PC, UHMW-PE
- Tolerance range
- ±0.02 mm to ±0.1 mm, depending on geometry
- Secondary operations
- Thread inserts, assembly, surface texturing, deburring
- Accepted design files
- STEP, STP, IGES, X_T, STL, DXF, PDF
Gripper product range
Common plastic robot gripper categories
Choose an application type as a starting point. Each component can be customized to your CAD, workpiece geometry, robot interface, and handling requirements.
Plastic Parallel Gripper Fingers
For standard pick-and-place and parallel-jaw applications.
Plastic Angular Gripper Fingers
Custom-angled profiles shaped around specific part geometry.
Plastic Robot Gripper Jaws
Precision-fit jaws for repetitive, high-cycle handling tasks.
Plastic Soft Gripper Inserts
Contact inserts selected for friction and surface protection.
Plastic Vacuum Gripper Plates
Custom-drilled plates with vacuum ports or integrated air channels.
Plastic Custom EOAT Fingers
Application-specific fingers for unique assembly requirements.
Plastic Product-Specific Grippers
Contoured to match workpiece dimensions and contact zones.
Plastic Food Handling Grippers
Food-safe material options available for suitable applications.
Plastic Non-Marring Grippers
Engineering plastics and contact designs selected to reduce marking.
Custom Robotic End-Effector Grippers
Integrated, drawing-led EOAT solutions for your automation cell.
Designed for your process
Performance starts with the right material
POM (Acetal)
Dimensional stability and low friction for precision fingers.
PEEK
High strength-to-weight ratio and heat resistance for demanding environments.
PA (Nylon)
Impact resistance and durability under repeated mechanical stress.
UHMW-PE
Wear resistance and low friction for sliding contact applications.
PC / ABS
High impact strength for protective housings and structural components.
Design for manufacturability
Review the details that affect grip, fit, and cycle time
Before production, our team reviews your CAD files for manufacturability and highlights design considerations that can support reliable factory-floor performance.
- 01
Wall thickness
Assess structural integrity under expected gripping pressure.
- 02
Mounting interfaces
Check bolt patterns, alignment features, and quick-change compatibility.
- 03
Weight and inertia
Identify opportunities to remove excess material and reduce robot-arm inertia.
- 04
Contact surface finish
Consider grip friction and non-marring needs for the workpiece surface.
From prototype to production
A practical route to production-ready EOAT
Support for one-off fit checks, early validation, small-volume machine builds, and repeat manufacturing for ongoing integration and maintenance needs.
Stage 01
Prototype
CNC-machined or 3D-printed samples for fit checks and functional testing.
Stage 02
Validate
Small-batch runs to assess material durability in real operating conditions.
Stage 03
Produce
Consistent, high-precision components for machine builds and line expansions.
Stage 04
Repeat manufacture
Ongoing supply for maintenance, repair, and integration projects.
A manufacturing partner for integrators
Custom grippers aligned to your automation cell
Based in Shenzhen, Plasticpartsmfg focuses on small-to-medium batch manufacturing for automation equipment. We prioritize technical accuracy, material traceability, and adherence to your engineering drawings—so the gripper is designed for your specific workpiece and tooling interface, not chosen from an off-the-shelf range.
- ✓Lightweight designs to help reduce robot-arm inertia
- ✓Soft-contact and non-marring surfaces for delicate parts
- ✓CAD-led vacuum ports, locating holes, and quick-change structures
- ✓Fast iteration for EOAT prototypes, small batches, and custom production
Common project questions
What files should I send for a quotation?
STEP or IGES files are preferred. Include material specifications, tolerance requirements, and any assembly or quick-change interface details.
Can you support prototypes as well as production batches?
Yes. The manufacturing path can cover prototype fit checks, small-batch validation, low-volume production, and repeat manufacturing.
Can a gripper include vacuum and quick-change features?
Vacuum interfaces, integrated channels, locating holes, and quick-change mounting features can be reviewed against your CAD design.
Request a quotation
Share your gripper design with our engineering team
Send your CAD files, material specifications, and tolerance or assembly requirements. Our team will review the project and provide a technical assessment and lead-time estimate.
Email your project files
info@plasticpartsmfg.com
Manufacturing facility
Building 1, No. 8, Chenggong Industrial Park, Kukeng, Longhua District, Shenzhen
Send an inquiry